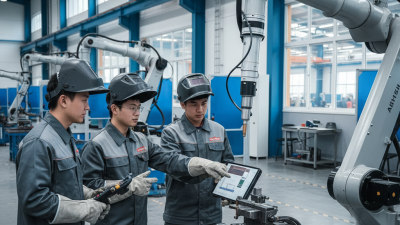
A Teaching Welding Robot is more than a mechanical arm holding a welding torch. It is a programmed production system that learns through guided movements, process settings, and repeatable inspection. An operator physically leads the robot through the required path or enters coordinates through a teach pendant. The controller records each position, speed, angle, and welding instruction. Later, the robot repeats those actions with consistent timing.
John C. Lippold, a respected welding metallurgy expert, offers a useful principle: “Automation cannot correct a poor welding process; it repeats it.” This idea explains why successful robotic welding begins with joint design, material preparation, torch access, and qualified welding procedures. A Teaching Welding Robot may produce clean beads across hundreds of parts. However, it still depends on correct wire feed speed, shielding gas, voltage, and fixture accuracy.
The process becomes clearer beside a real workstation. A steel bracket enters a fixture. Clamps hold it firmly. The robot approaches, strikes the arc, follows the programmed seam, and returns to its home position. Sensors and inspection tools may check alignment or weld quality afterward. Yet the system is not flawless. Distortion, spatter, worn contact tips, and small fixture changes can affect results. That limitation matters.
This article explains what a Teaching Welding Robot is, how teaching methods work, and where human judgment remains essential. It also examines setup requirements, operating benefits, common errors, and practical safety considerations. The goal is not to present automation as effortless. It is to show how disciplined preparation makes robotic welding more reliable.
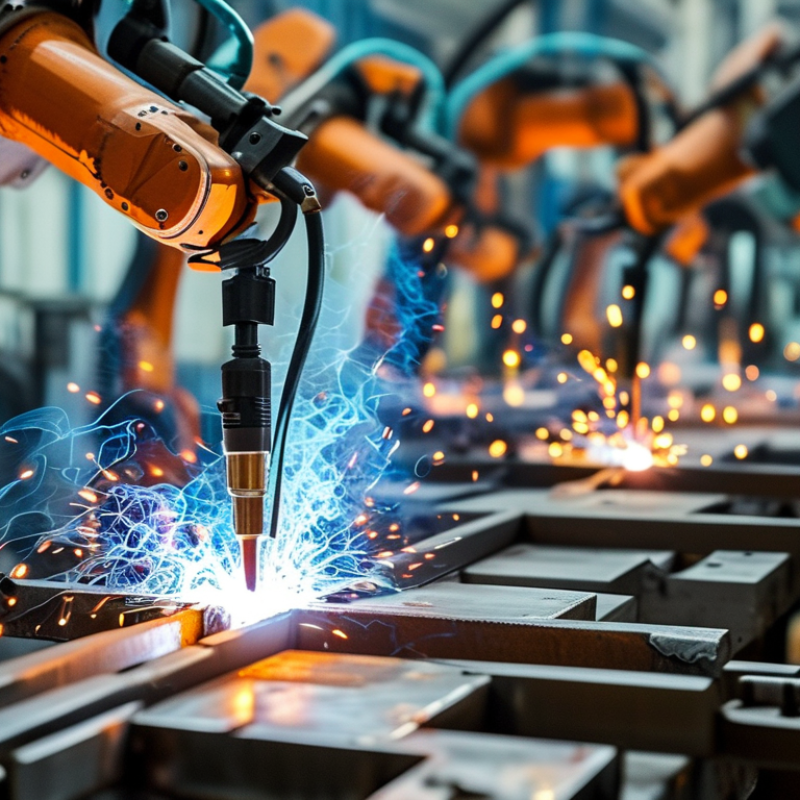
A teaching welding robot is an industrial robotic system programmed to repeat welding movements. It combines a mechanical arm, welding equipment, a controller, and a teaching device. The operator guides the torch through selected positions or enters movement commands manually. The robot then stores these points as a welding program.
During teaching, the operator places the torch near the joint and records approach, start, weld, and retreat positions. The program can include travel speed, arc voltage, wire feed rate, and welding time. The controller connects these instructions with the workpiece coordinate system. It calculates smooth paths between recorded points. Small errors matter here. A poorly chosen angle can cause spatter, undercut, or incomplete fusion.
Modern systems may use touch sensing, seam tracking, or vision sensors to adjust the path. These tools help when parts vary slightly, but they do not replace skilled setup. Fixtures must hold components firmly, and cables must avoid sharp bends or collision points. Safety depends on guarded zones, tested programs, emergency stops, and controlled restart procedures. It is not a robot that learns by itself.
In real production, teaching often requires several trial runs. An experienced technician watches the arc, listens for instability, and checks the finished bead. Yet even experienced staff can overlook heat distortion or access limits. That weakness deserves review before full-speed operation. A reliable program is not only fast; it produces consistent welds under changing shop conditions.
What Is a Teaching Welding Robot and How Does It Work?
A teaching welding robot is an industrial arm programmed by human guidance. An operator moves the torch through each weld path. The controller records positions, speed, angle, and welding conditions. Later, the robot repeats those instructions with consistent motion. This method is useful for medium-volume production, but it is not fully automatic intelligence. Poor teaching still produces poor welds.
The manipulator provides controlled movement across several axes. Its controller converts taught points into coordinated motion. A teach pendant lets operators adjust paths beside the workpiece. The welding power source controls current and voltage. A wire feeder delivers filler metal at a selected rate. The torch maintains the arc, shielding gas, and contact distance. A work positioner can rotate the component for better access. Small errors matter.
Sensors can detect joint location, torch height, or arc conditions. A safety enclosure, interlocks, and emergency stops protect nearby workers. According to the International Federation of Robotics, 541,302 industrial robots were installed worldwide in 2023, showing wider industrial adoption (World Robotics 2024). Welding remains demanding because heat causes distortion and changing gaps. Industry reports often emphasize productivity, yet training quality receives less attention. In practice, an experienced welder may need several adjustments before the path becomes stable. Even then, fixtures, material variation, and maintenance can challenge repeatability.
A teaching welding robot learns a welding path through guided movement, recorded points, and controlled repetition. The operator moves the torch along the joint, either by hand-guiding the arm or using a teaching pendant. The controller records position, speed, torch angle, and welding sequence.
Small details matter. A corner may need slower travel. A gap may require a wider weave. The robot stores these instructions as a motion program, then repeats them with consistent timing. According to the International Federation of Robotics’ World Robotics 2024 report, factories installed 541,302 industrial robots worldwide in 2023. This growth reflects demand for stable, repeatable production, including welding applications.
The learning process is not completely automatic. An experienced welder must check arc stability, wire placement, shielding gas, and heat input. A path that looks correct on screen can still produce undercut, porosity, or uneven penetration. That is the uncomfortable part.
Real joints are rarely perfect.
Sensors can detect seam changes and help adjust the torch during welding. However, sensing accuracy depends on surface condition, lighting, joint design, and calibration. The American Welding Society emphasizes procedure control, qualification, and inspection in robotic welding practice. Therefore, operators should test the taught path on sample parts before production. They should also review weld appearance and inspection results after each adjustment. The robot repeats instructions faithfully, including mistakes.
| Teaching Stage | Action Performed by the Operator | Main Data Captured by the Robot | How the Data Is Used During Welding |
|---|---|---|---|
| 1. Workpiece Preparation | Secure the parts in a fixture and place them in a repeatable position. | Workpiece location, joint type, access direction, and fixture reference. | Provides a stable physical reference so the programmed path matches the actual assembly. |
| 2. Tool Center Point Setup | Define the electrode or welding torch tip as the tool center point, commonly called the TCP. | TCP position and torch orientation relative to the robot wrist. | Allows the controller to calculate the actual torch-tip position while each robot joint moves. |
| 3. Coordinate Frame Selection | Select a suitable coordinate system, such as the robot base, tool, or workpiece frame. | Reference frame, origin, axes, and orientation. | Makes jogging and path programming consistent with the workpiece geometry. |
| 4. Manual Jogging | Use a teach pendant to move the torch to the beginning of the weld joint. | Robot position, torch angle, approach direction, and stand-off distance. | Establishes the starting pose and reduces the risk of collisions during the approach. |
| 5. Weld Start Point | Record the first taught point at the correct location before arc initiation. | Position, orientation, approach motion, and programmed start conditions. | Defines where the robot moves into position and where the welding sequence begins. |
| 6. Intermediate Path Points | Jog the torch along the joint and record additional points where the direction or geometry changes. | Multiple positions, orientations, travel directions, and motion transitions. | Creates a sequence that approximates the intended weld centerline and torch movement. |
| 7. Weld End Point | Record the final point and define the end-of-weld movement. | End position, crater-fill or finishing conditions, and retract direction. | Controls weld termination and moves the torch away from the part safely. |
| 8. Motion Interpolation | Choose how the controller moves between taught points. | Joint motion or Cartesian linear motion, speed, acceleration, and blending settings. | Determines whether the torch follows a straight, smoothly blended, or joint-optimized movement. |
| 9. Welding Parameters | Enter or select the process settings for the weld procedure. | Welding current, voltage, wire feed speed, travel speed, shielding gas, and arc timing. | Synchronizes the robot motion with the power source and the required welding process. |
| 10. Weaving Pattern | Add a controlled weave when the joint design or weld size requires lateral torch movement. | Weave width, frequency, dwell time, and weave shape. | Distributes heat and filler metal across the joint instead of maintaining a single narrow line. |
| 11. Seam Detection or Tracking | Enable a suitable sensor when joint location may vary between workpieces. | Arc signals, laser measurements, touch-sensing results, or other seam-location feedback. | Allows the robot to correct the programmed path during operation when permitted by the control system. |
| 12. Dry-Run Verification | Run the program without welding or with the process output disabled. | Simulated path, clearance distances, cycle sequence, and robot reach. | Helps identify collisions, singularities, excessive axis rotation, and incorrect approach movements. |
| 13. Low-Speed Trial | Execute the program at reduced speed while observing the torch and workpiece. | Actual robot motion, torch clearance, arc start behavior, and fixture interaction. | Confirms that the taught path is safe and that the torch remains correctly oriented along the joint. |
| 14. Weld Inspection | Inspect the completed weld and adjust the path or process settings if necessary. | Bead appearance, penetration indicators, weld dimensions, spatter, and defect observations. | Improves repeatability and helps bring the weld into compliance with the applicable procedure. |
| 15. Program Storage and Reuse | Save the verified program and document the setup conditions. | Motion points, process parameters, work offsets, tool data, and safety settings. | Enables the robot to reproduce the welding cycle for consistently positioned workpieces. |
A teaching welding robot learns a weld path through guided programming. An operator moves the torch with a teach pendant or manually guides the arm. The controller records positions, torch angles, travel speed, and welding points. It also stores workpiece coordinates and approach distances. This creates a repeatable digital path. Small details matter. A two-millimeter gap can change the finished bead.
During production, the robot recalls these programmed points and moves through them in sequence. Its controller coordinates arm motion, wire feeding, shielding gas, and arc initiation. Welding power settings usually include current, voltage, travel speed, and wire-feed rate. Sensors can monitor arc voltage, joint position, and torch distance. If feedback changes, the controller may adjust movement or welding output. According to the International Federation of Robotics’ World Robotics 2024 report, 541,302 industrial robots were installed globally in 2023. This expanding installed base reflects stronger demand for controlled, repeatable production.
A teaching robot does not simply “press start.” The operator must check fixture alignment, joint cleanliness, torch calibration, and program safety. A well-taught path can produce consistent penetration and bead appearance. However, consistency is not the same as quality. Poor teaching reproduces poor work quickly. That is the uncomfortable part. Welders should inspect samples, review process data, and revise programs when distortion or spatter appears. The robot follows instructions precisely, but it cannot fully understand a changing joint without suitable sensing and human judgment.
A teaching welding robot learns a weld path through a teach pendant or guided torch movement. An operator records positions, travel speed, torch angle, and welding pauses. The controller then repeats these instructions on similar workpieces. In a fabrication shop, this method suits frames, brackets, pipes, and other repetitive assemblies. The operator still checks joint fit-up, wire condition, shielding gas, and fixture alignment. Small errors matter.
The main benefit is consistent movement across long production runs. The robot can maintain a steady travel speed and reduce exposure to heat, fumes, and welding glare. It also helps skilled welders spend more time on complex joints and quality checks. With proper fixtures, production becomes easier to measure. Some setups are awkward. Teaching can take time when access is tight or parts vary slightly.
Limitations become clear when components arrive warped, dirty, or poorly positioned. A robot may repeat the programmed path but miss the joint. Sensors can support correction, yet they do not replace sound process knowledge. Welding engineers should test penetration, bead shape, distortion, and fixture repeatability before regular operation. Maintenance also matters, including torch cleaning, cable inspection, and calibration. A perfectly repeated mistake remains a mistake. Human review is still necessary, especially during the first production runs.